Robots
The robot platforms I have worked with: mobile robots I have made autonomous, robotic arms I have programmed, and the robots I built for ABU Robocon.
Autonomous Mobile Robots
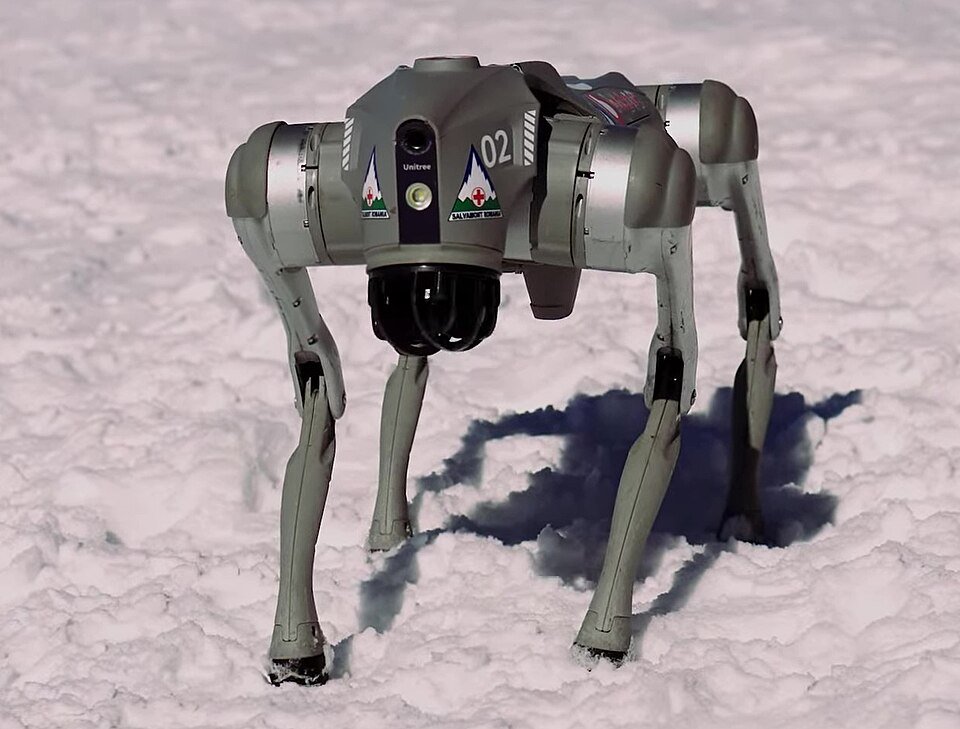
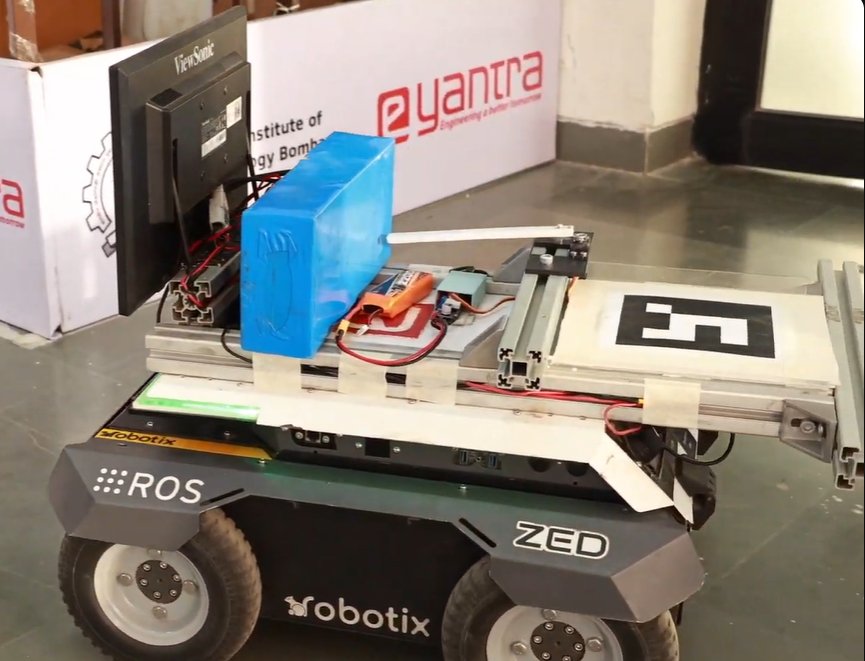
I have implemented autonomous navigation on a wide range of drive configurations, from quadrupeds to skid-steer and holonomic bases, in both indoor and outdoor environments. The work covers localization, mapping, path planning and control across the whole range of stacks: custom navigation stacks written from scratch, fully autonomous execution running entirely on microcontrollers, and Nav2. I have plenty of experience with ROS. That is not the same as liking it.
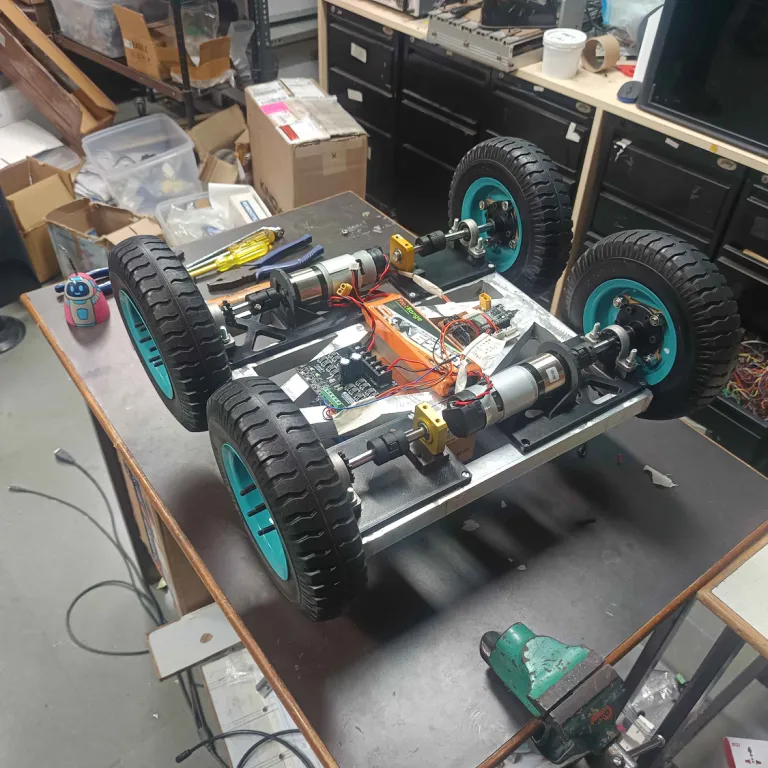
Modular Skid-Steer Base
A custom-built base with a 20 kg payload capacity and a universal mounting plate, running Nav2. Built with my interns.

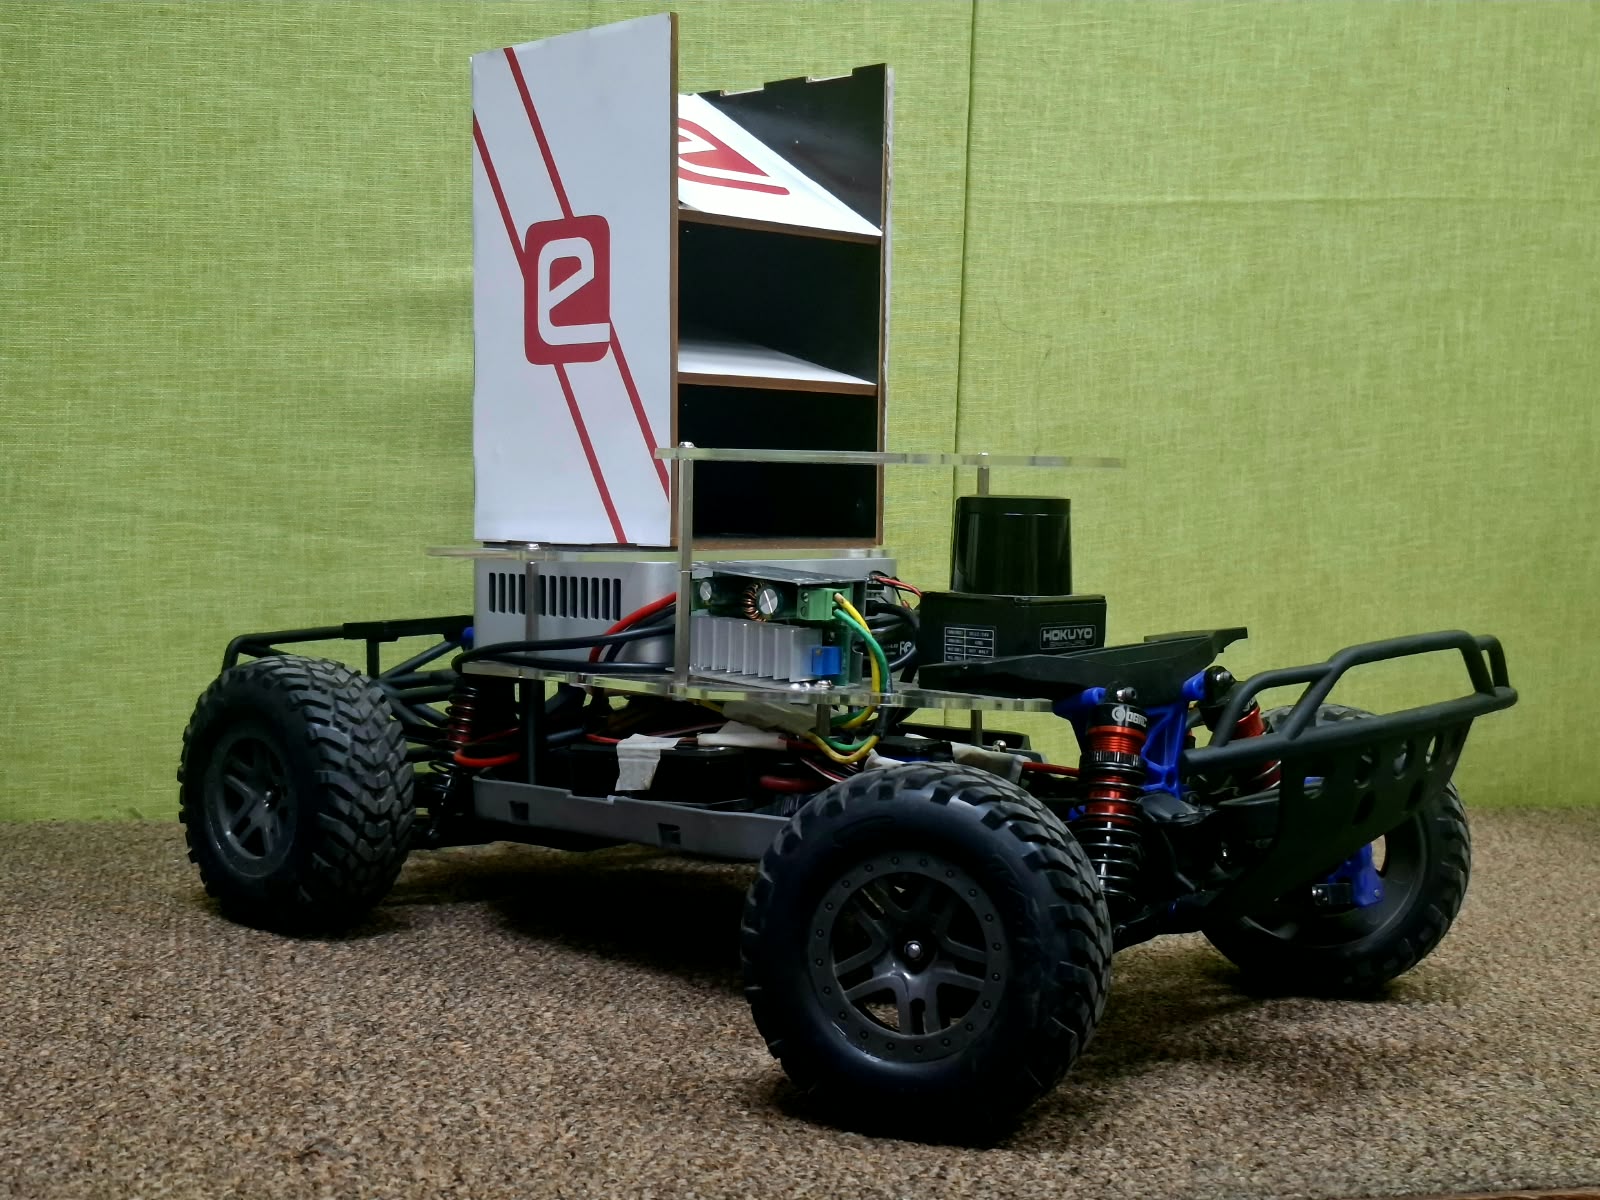
F1TENTH Race Car
A 1/10-scale autonomous race car that follows an optimized raceline. Read more
Robotic Arms
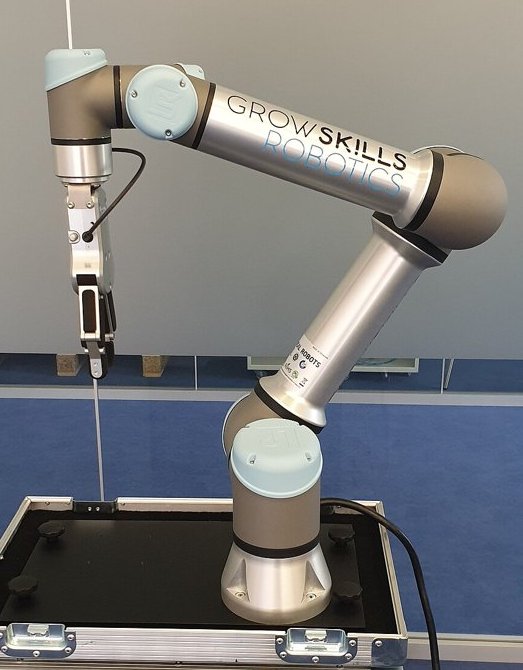
The UR5 is the collaborative arm at the centre of the e-Yantra Robotics Competition themes I developed, Cosmo Logistic and Logistic coBot. In these themes, students program it through ROS 2 to pick and place payloads, working together with the eBot mobile robot in a warehouse setting. Read more
ABU Robocon
The robots I built with Team Rudra for ABU Robocon, the Asia-Pacific robotics contest where each year’s game sets a new challenge.
2023: Supervising the team
I supervised the electronics and programming of both robots. Each was semi-automatic, a fully closed-loop system with a Teensy 4.1 as the main controller. Their task was to pick up rings and throw them onto targets to score as many points as possible.
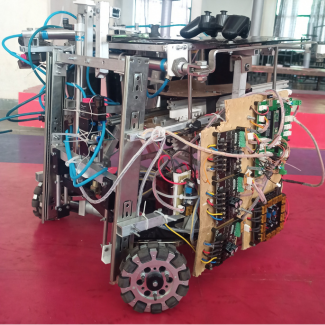
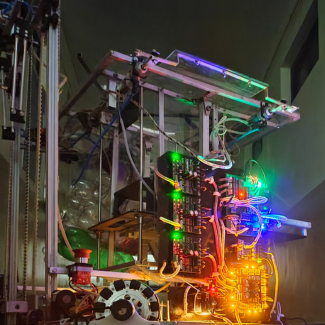
2022: Electronics, programming and operating
I was responsible for the electronics and programming of both robots. Each was semi-automatic with a fully automatic mode, and each was a closed-loop system with active feedback on every mechanism, built around an ARM Cortex-M7 Teensy 4.1. I also operated Robot 1 at the official competition.
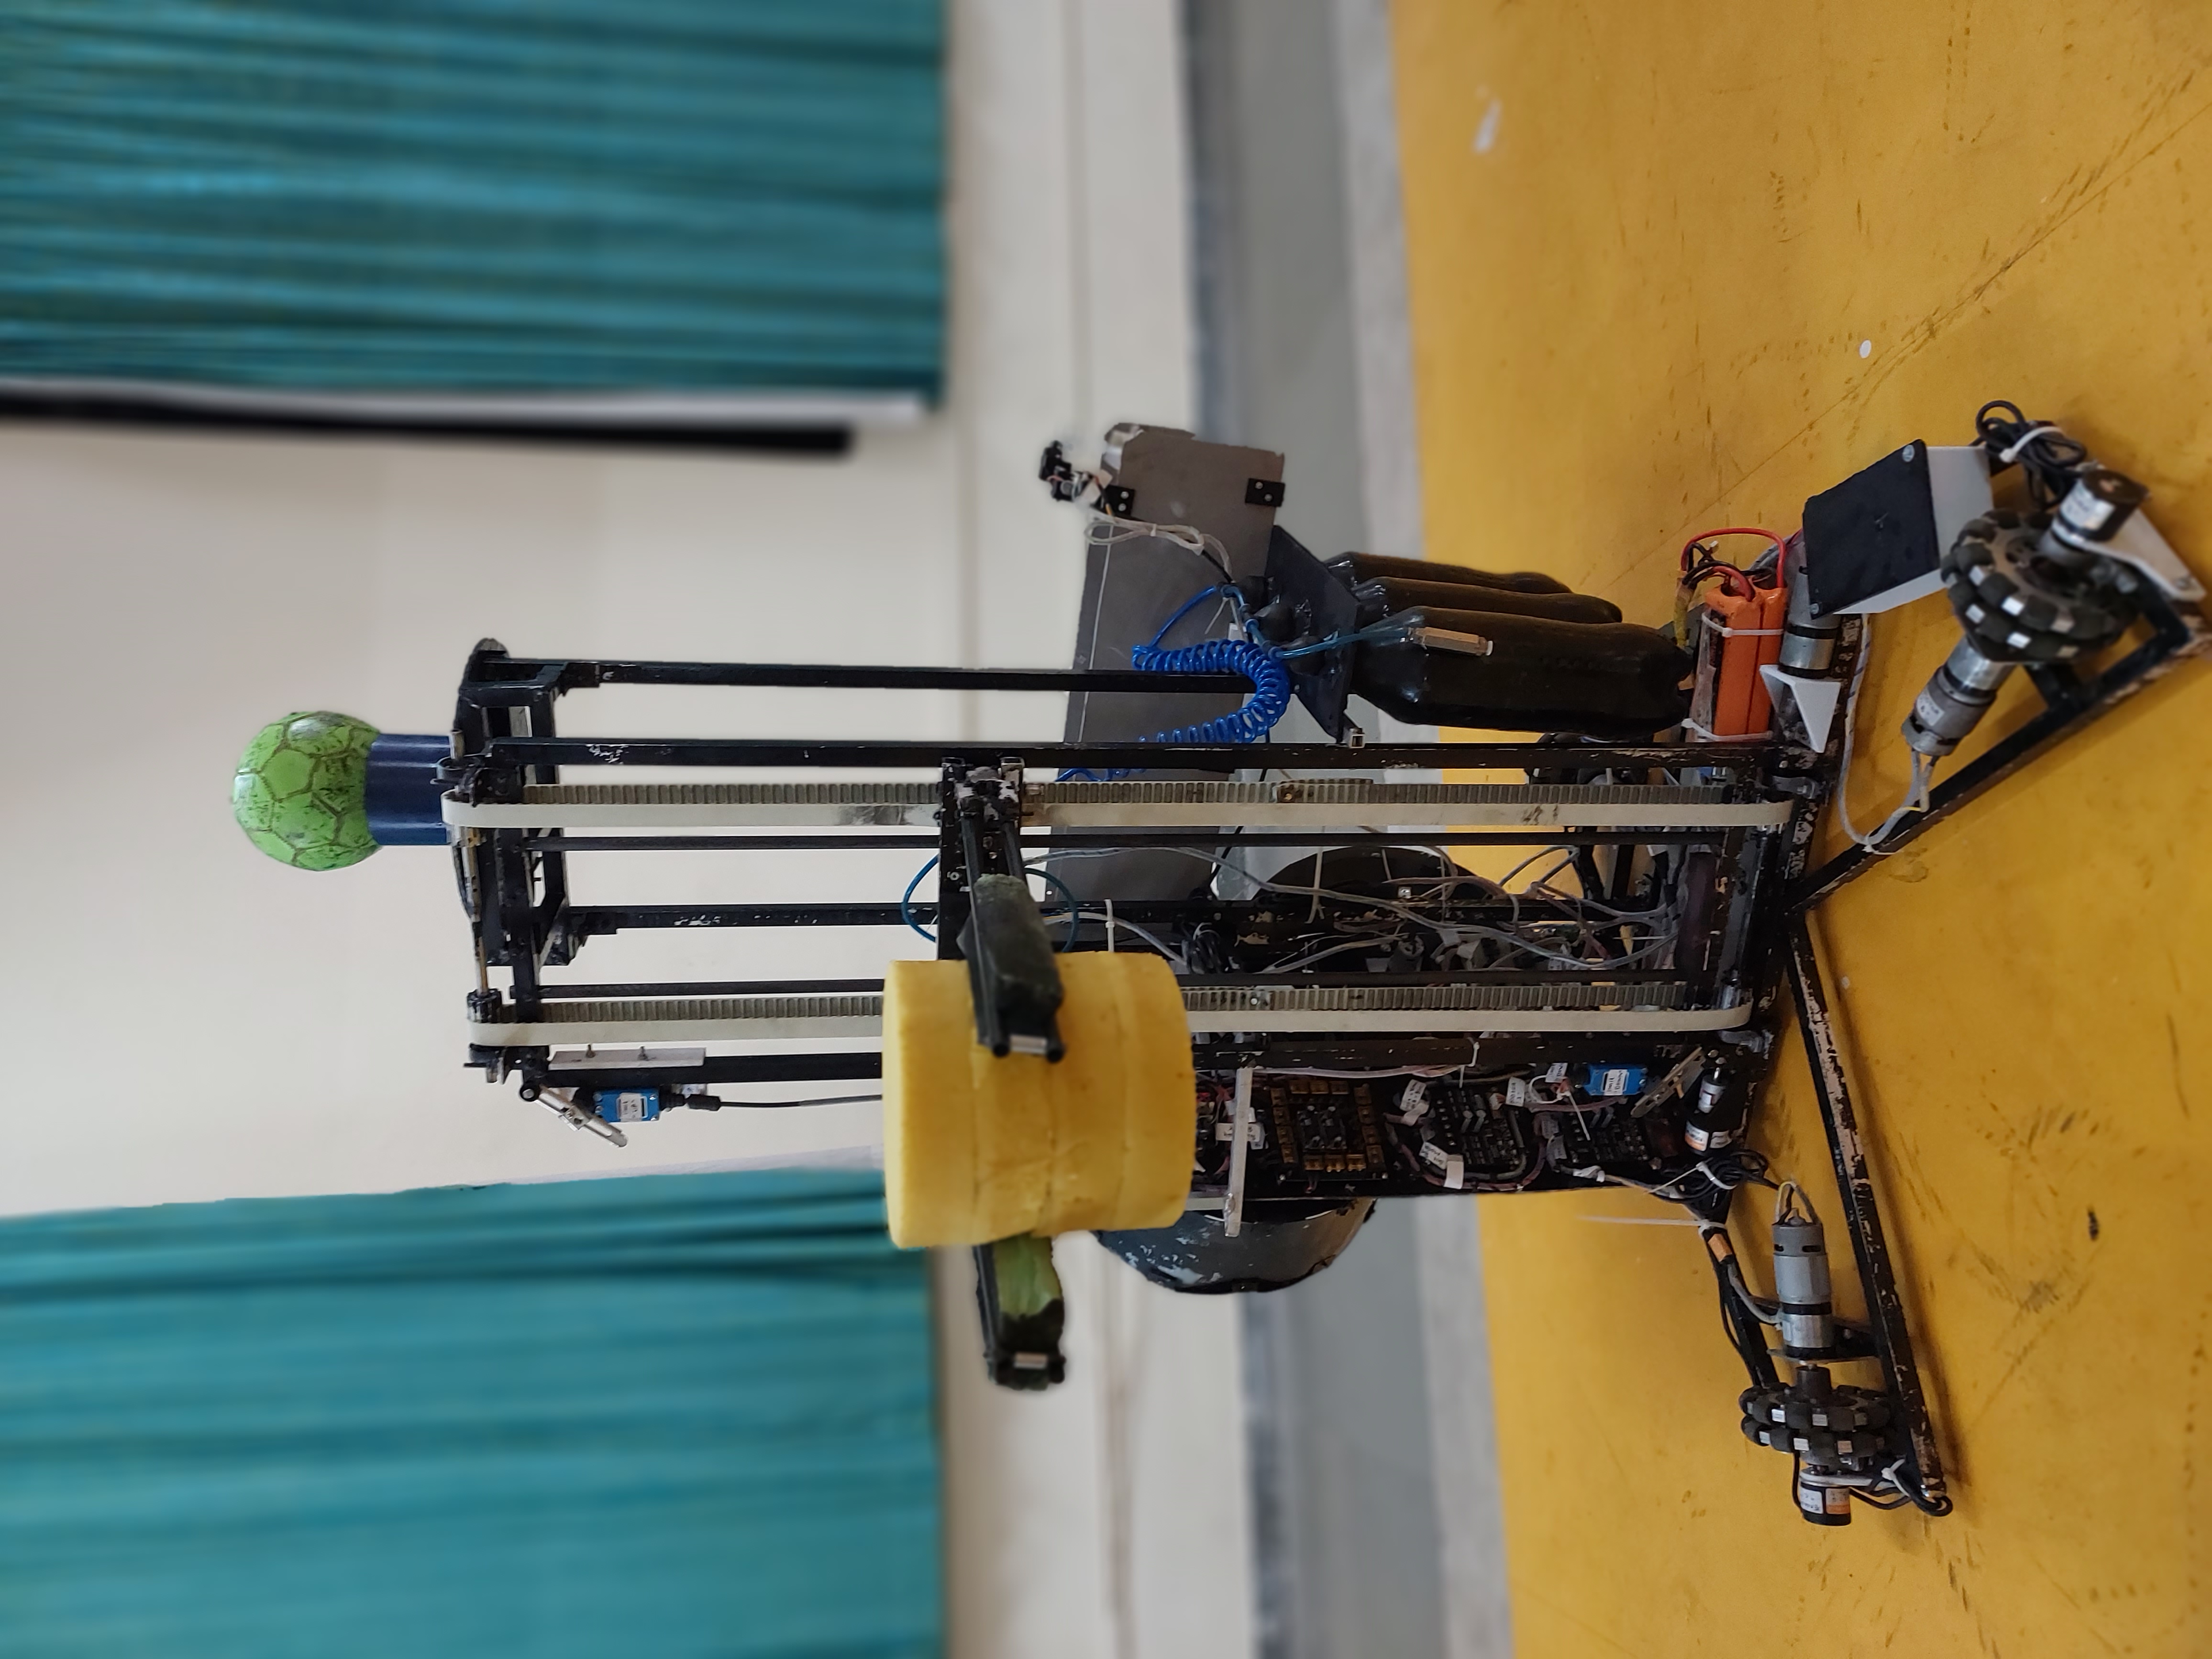
2021: My first robots
Both robots were semi-automatic with a fully automatic mode, and each was a closed-loop system with an ATmega2560 as the main controller. I was responsible for their programming and automation.
Image credits: UR5, “Cobot.jpg” by GrowSkills Robotics, CC BY-SA 4.0, cropped, via Wikimedia Commons. Unitree Go2, “Unitree Go2 of Salvamont front view” by HotNews Romania (Adi Iacob, Ovidiu Popica), CC BY 3.0, via Wikimedia Commons.

